Hi there! I'm a third-year PhD candidate (Aug. 2024 - ) at School of Computing, NUS, advised by Prof. Lin Shao. I am supported by the President's Graduate Fellowship (PGF).
I'm a visiting PhD student at UC Berkeley with Toru Lin and Prof. Jitendra Malik.
I obtained my B.Eng. (Sep. 2020 - Jun. 2024) in Robotics from Zhejiang University, where I had the privilege of working with Kechun Xu, Prof. Rong Xiong, and Prof. Yue Wang.
I expect to graduate in 2027 and am seeking research opportunities in academia and industry, with a focus on dexterous manipulation and robot learning.
News- Sep 2026 FingerEye and T(R,O) Grasp++ accepted to CoRL 2026, with FingerEye selected for a Spotlight Presentation!
- Jun 2026 Web2Grasp and QuaMa accepted to IROS 2026.
- Jan 2026 T(R,O) Grasp accepted to ICRA 2026.
- Dec 2025 Research Achievement Award (2025 - 2026), NUS School of Computing.
- Dec 2025 Passed PhD qualification exam — officially a PhD candidate!
- Nov 2025 DexSinGrasp accepted to RA-L.
- Jun 2025 MetaFold accepted to IROS 2025 as Oral Presentation!
- May 2025 D(R,O) Grasp selected as Best Paper Award on Robot Manipulation and Locomotion @ ICRA 2025. TelePreview selected as Best Paper Award @ ICRA 2025 Workshop on Human-Centric Multilateral Teleoperation.
- Apr 2025 D(R,O) Grasp selected as the Finalist of Best Paper Award & Best Paper Award on Robot Manipulation and Locomotion @ ICRA 2025.
- Jan 2025 D(R,O) Grasp accepted to ICRA 2025.
- Jan 2025 FLIP accepted to ICLR 2025.
- Nov 2024 D(R,O) Grasp selected as Best Robotics Paper Award @ CoRL 2024 Workshop MAPoDeL!
- Aug 2024 I am honored to funded by President's Graduate Fellowship (PGF).
- Jun 2024 ManiFM accepted to IROS 2024 as Oral Presentation!
- Aug 2023 Diff-LfD accepted to CoRL 2023 as Oral Presentation!
Research Highlights
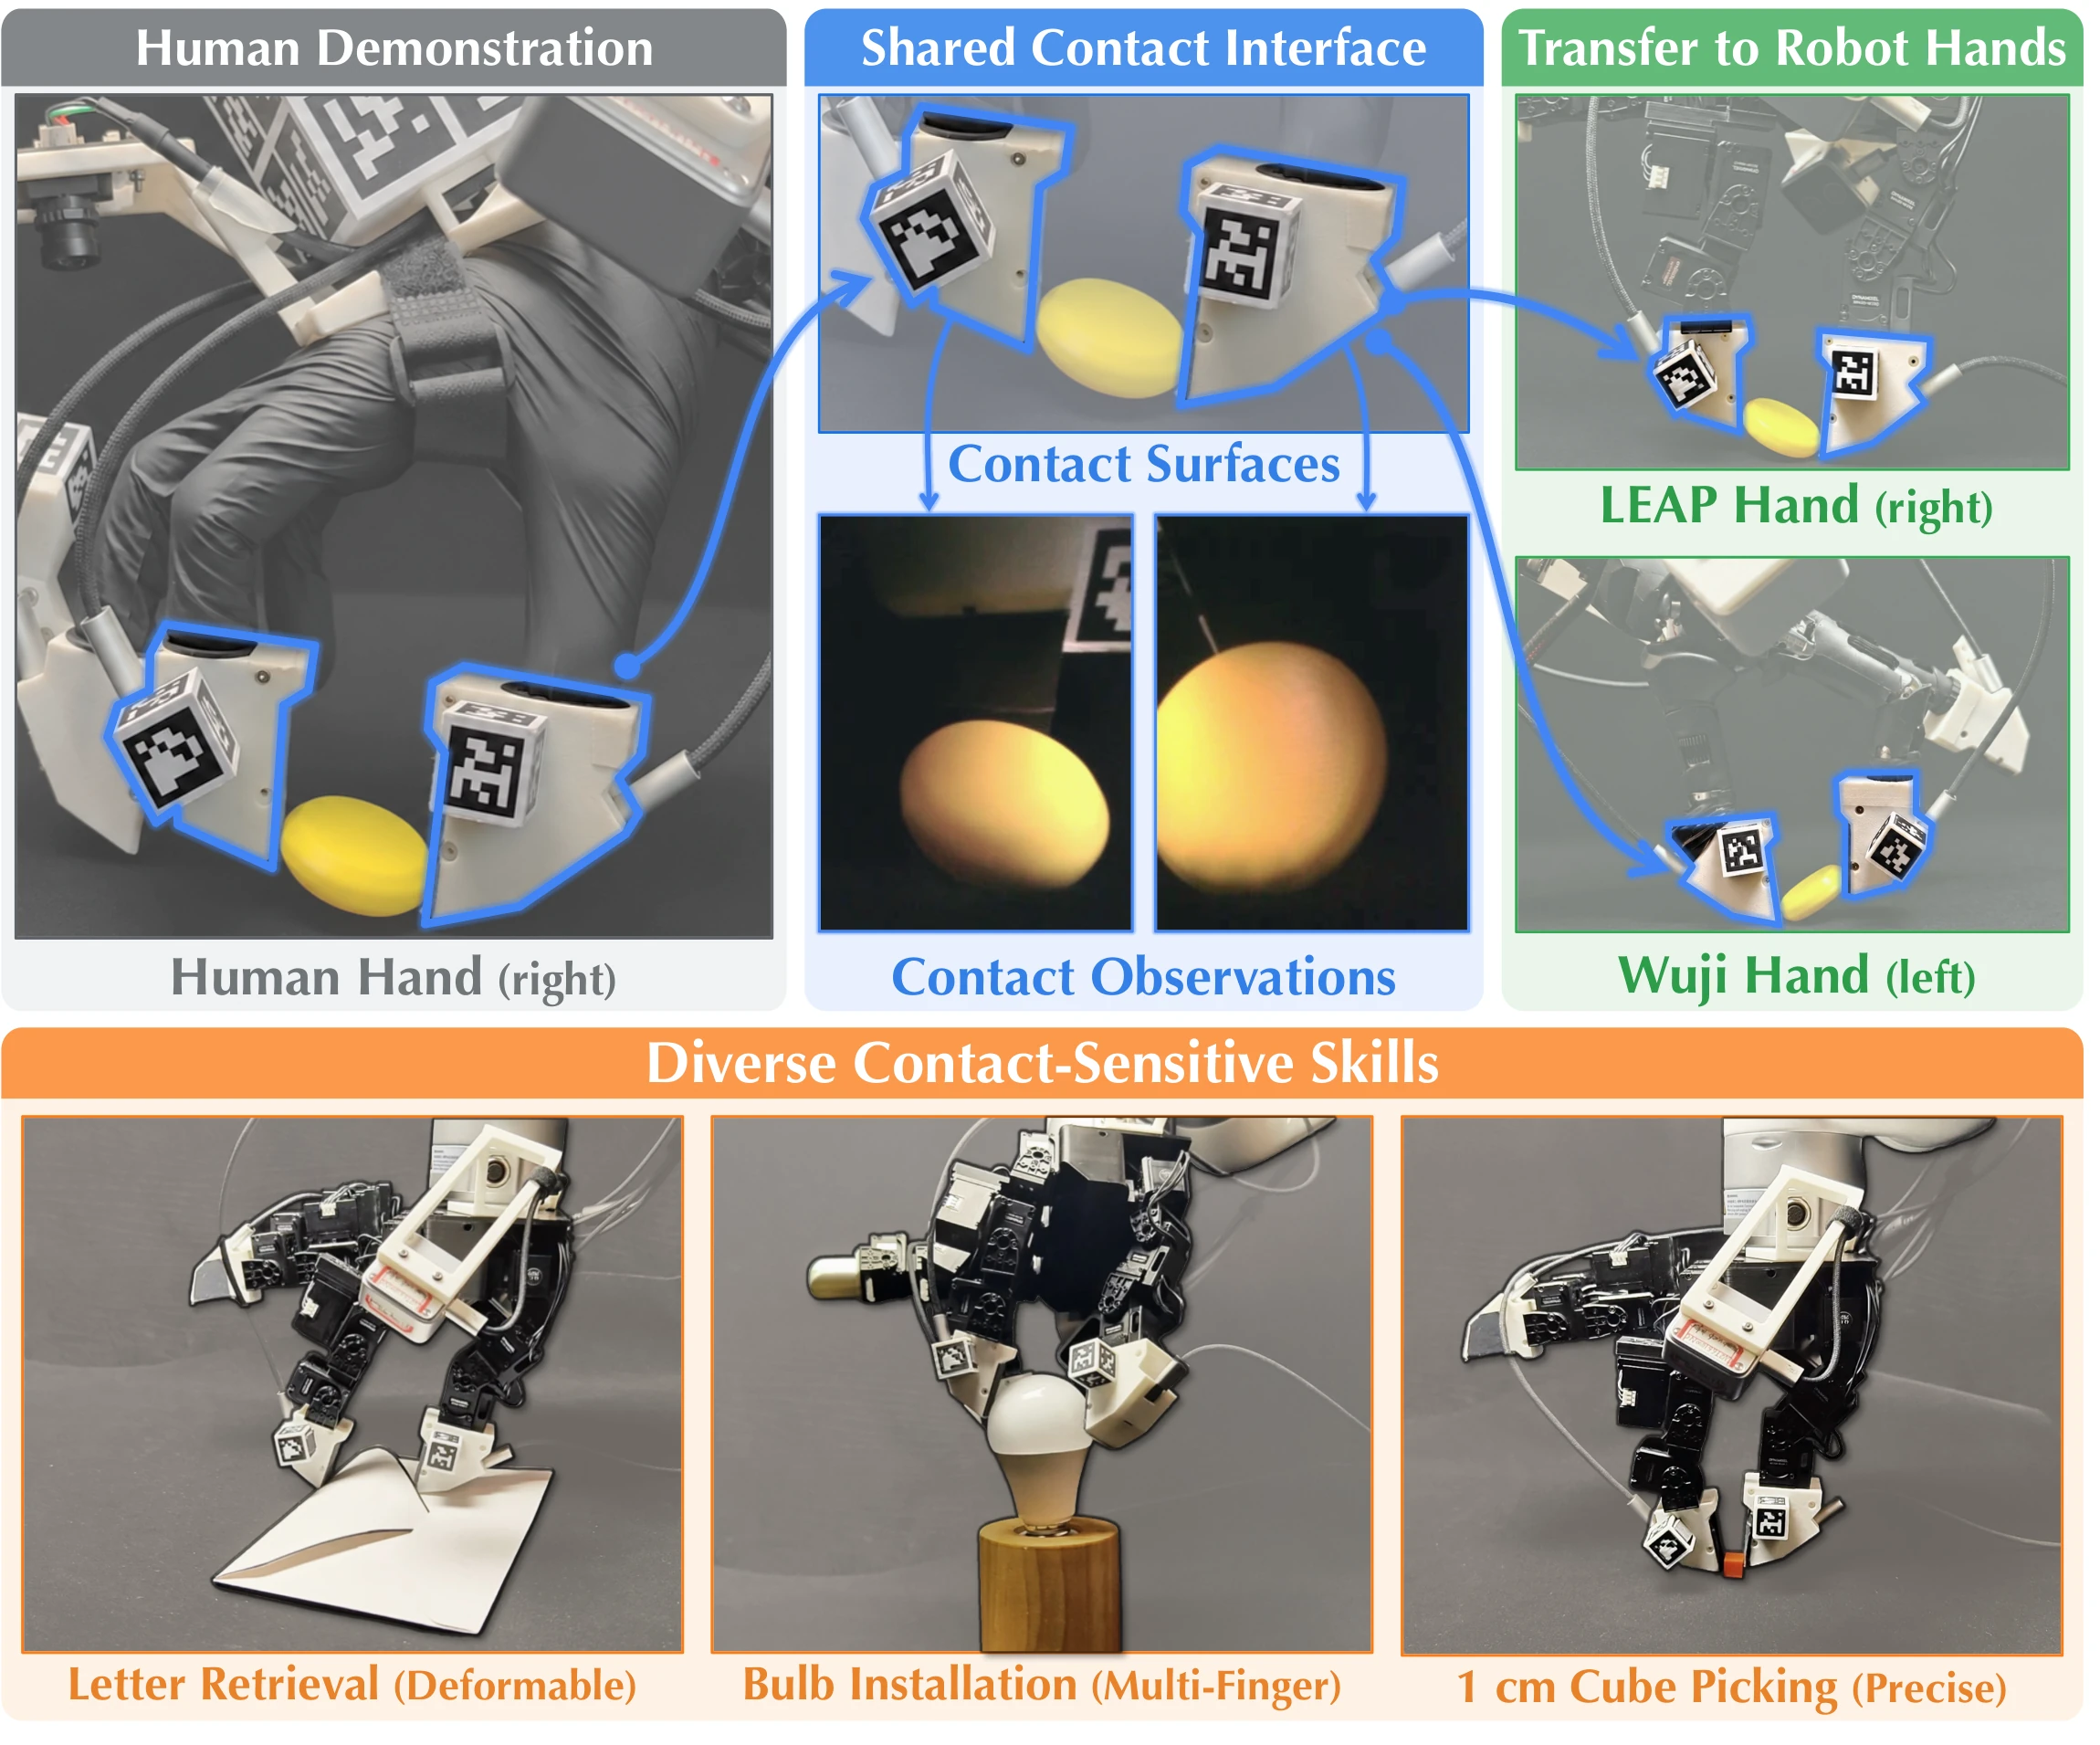
CIMI: Contact Imitation Interface — Transferring Dexterous Skills by Showing How Contact Unfolds
Transfer dexterous skills from robot-free human demonstrations across robot hands using shared contact geometry and fingertip RGB views.
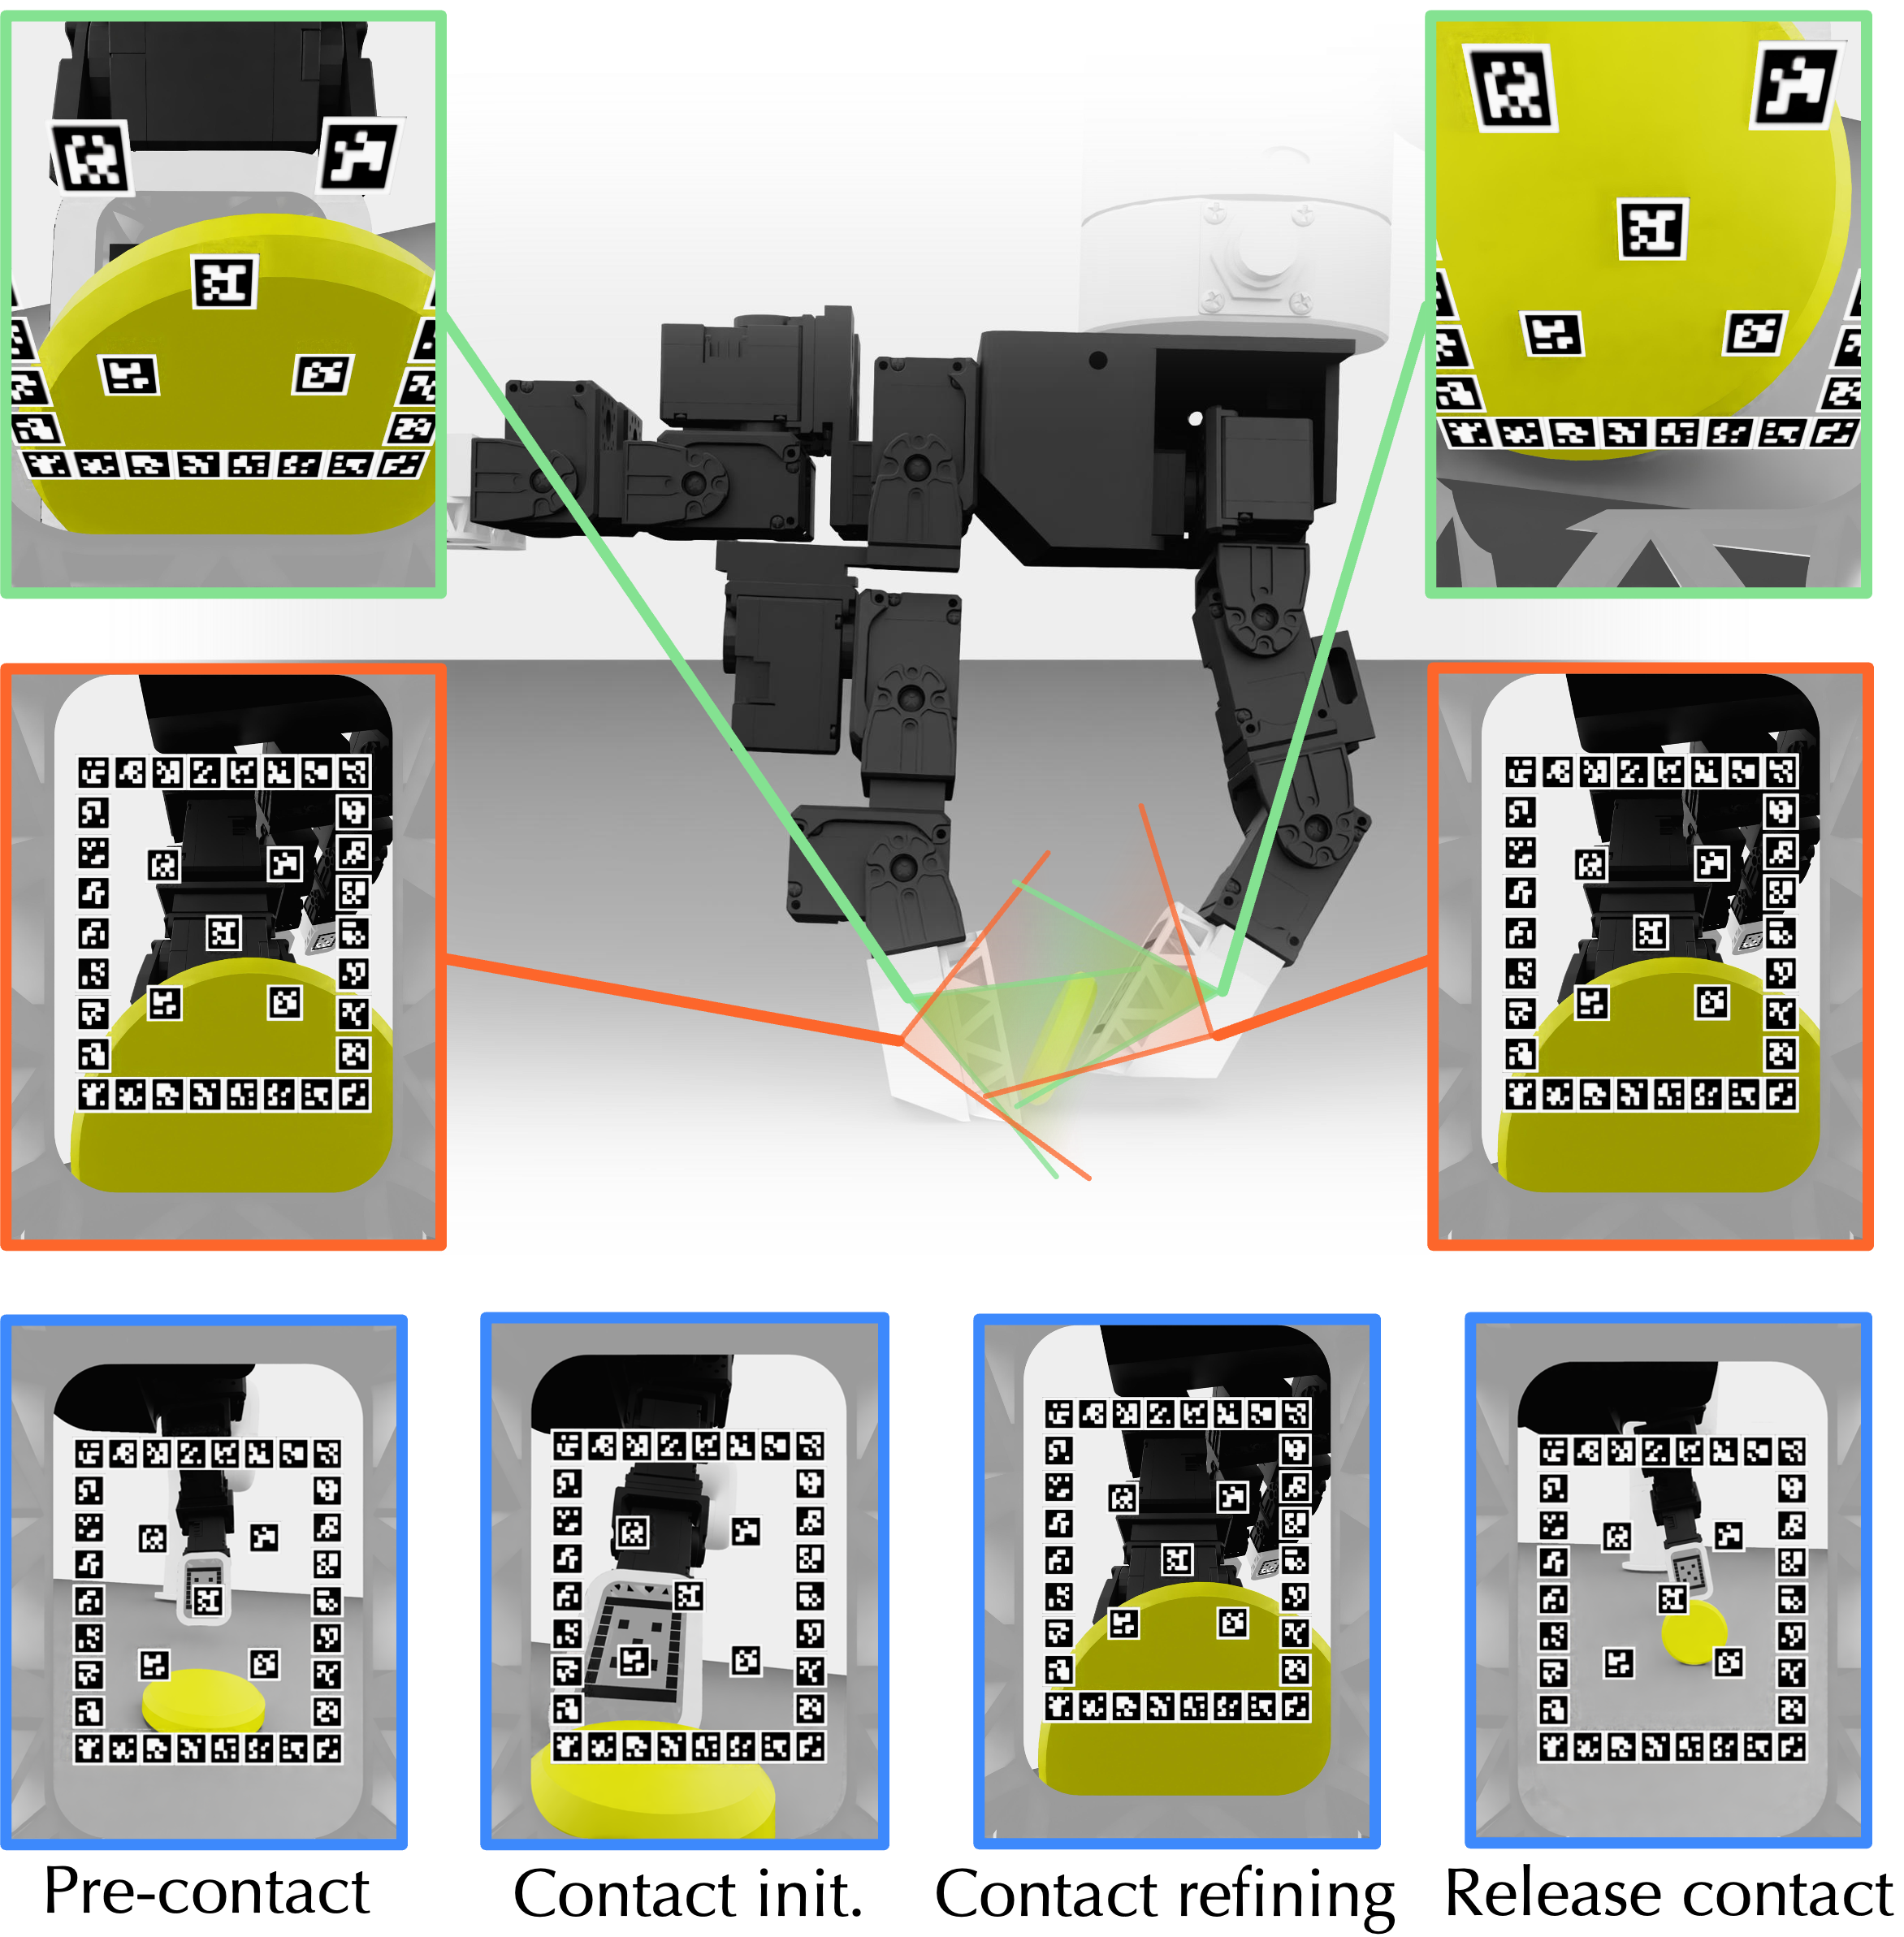
FingerEye: Learning Dexterous Manipulation with Continuous Vision-Tactile Sensing
Conference on Robot Learning (CoRL) 2026
Spotlight Presentation
Combine fingertip binocular vision with contact-wrench cues from compliant-ring deformation for dexterous manipulation.
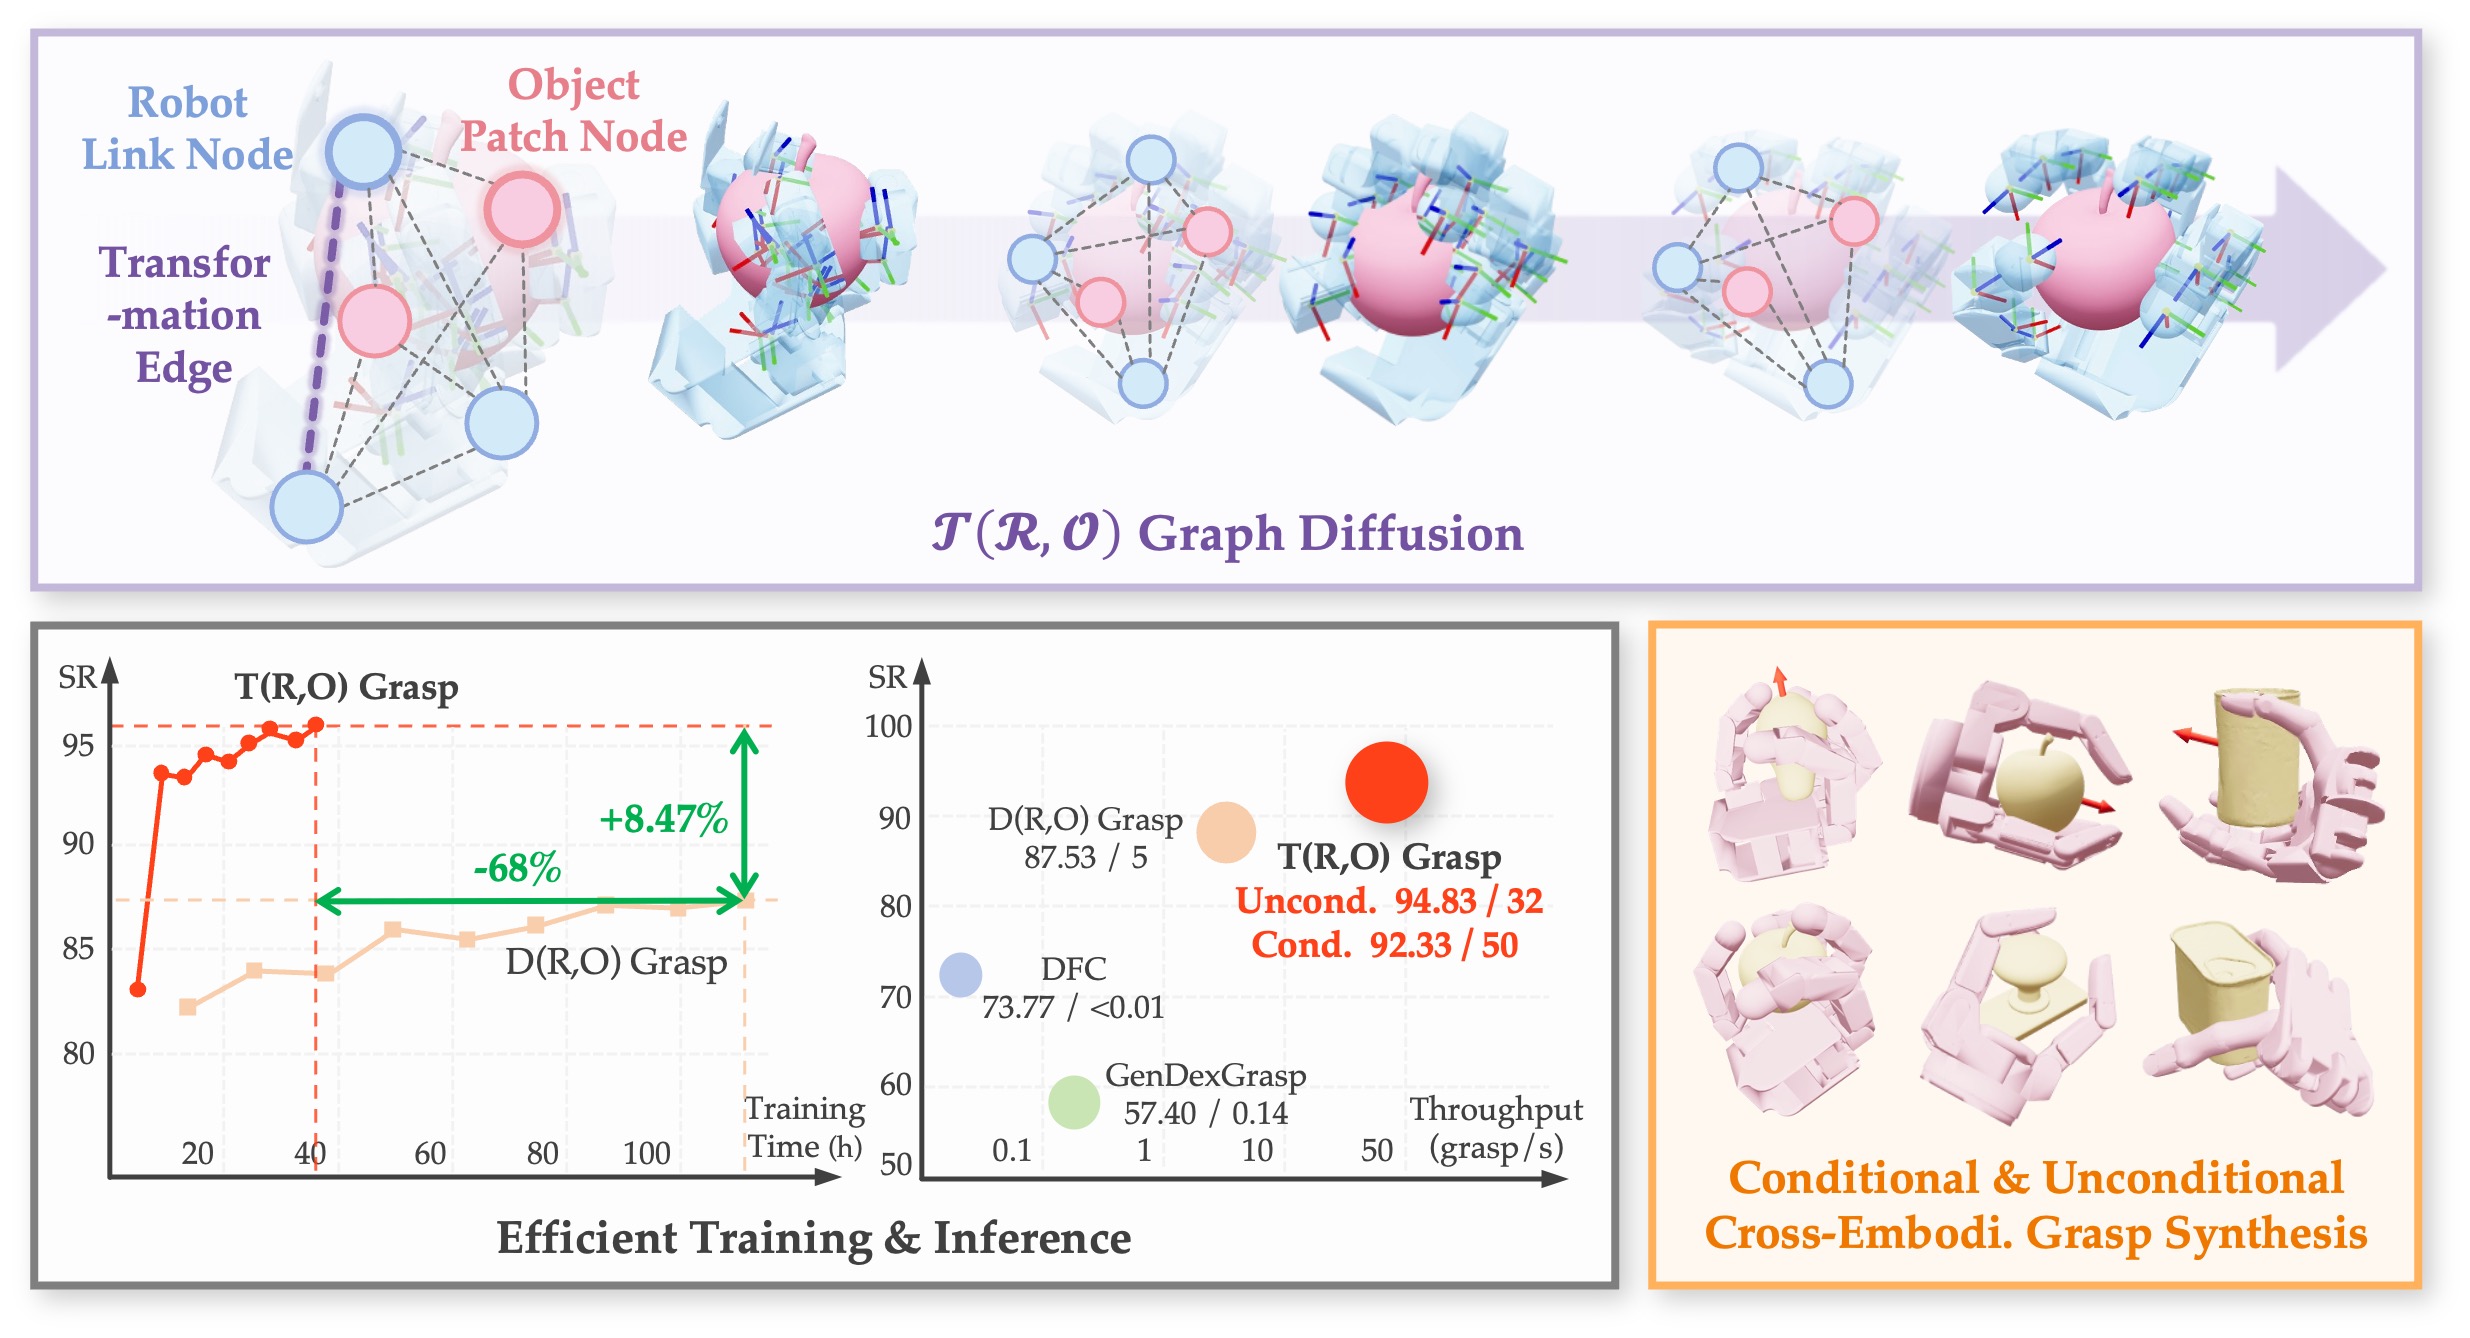
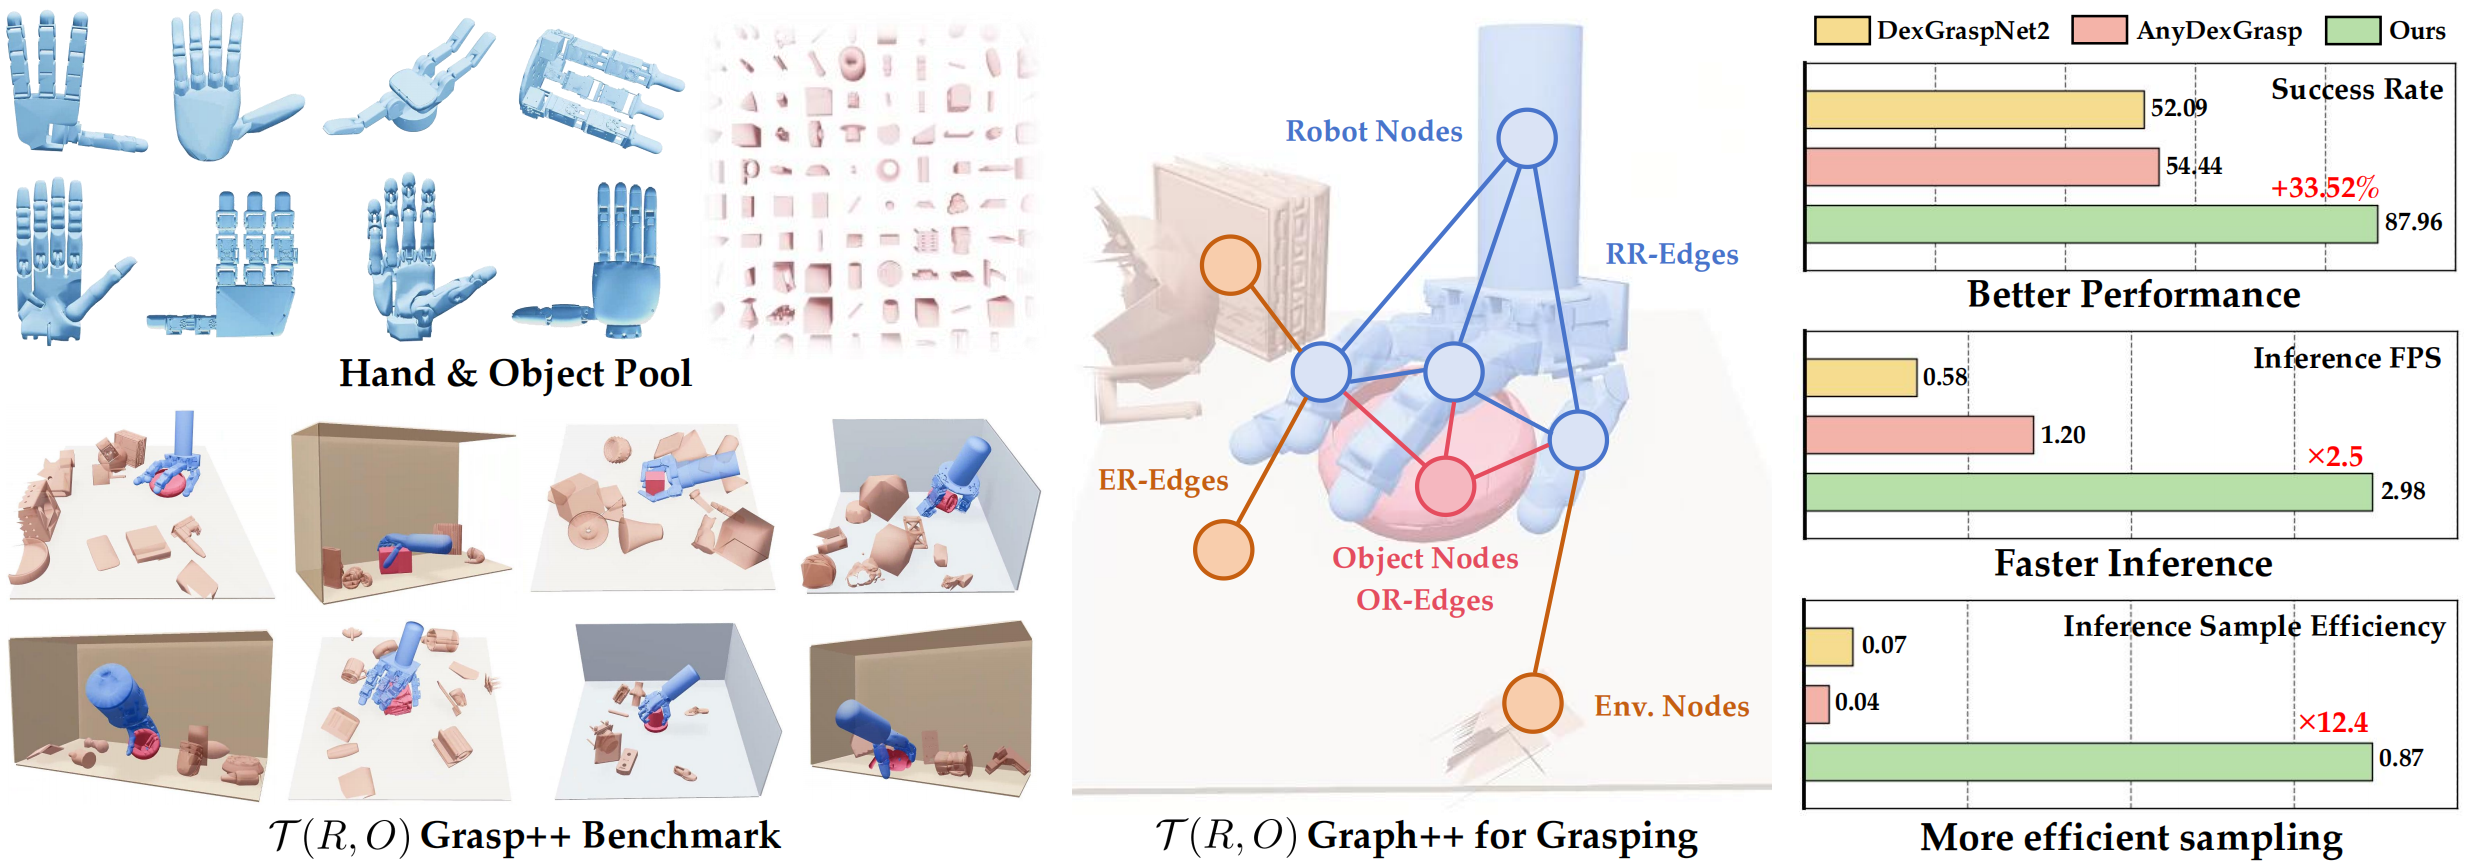
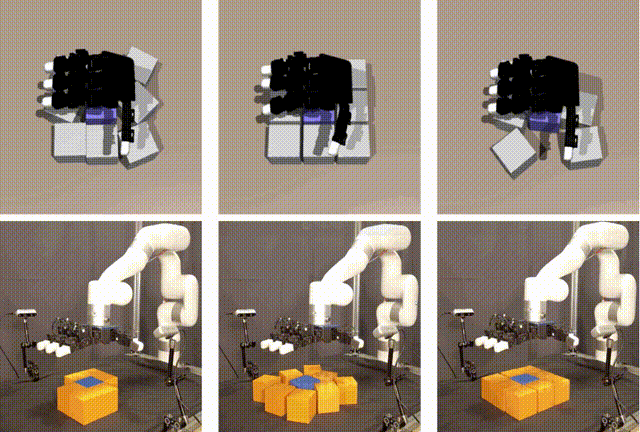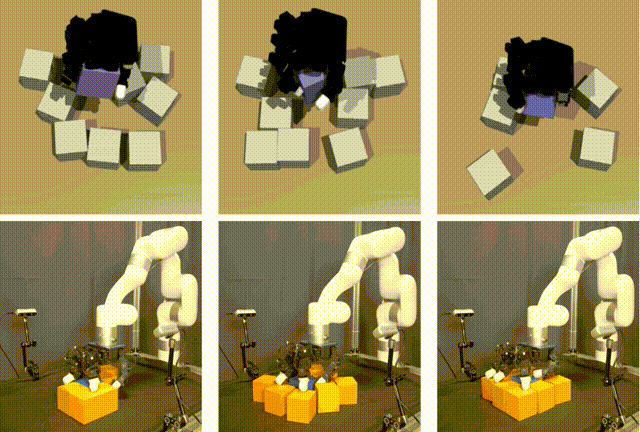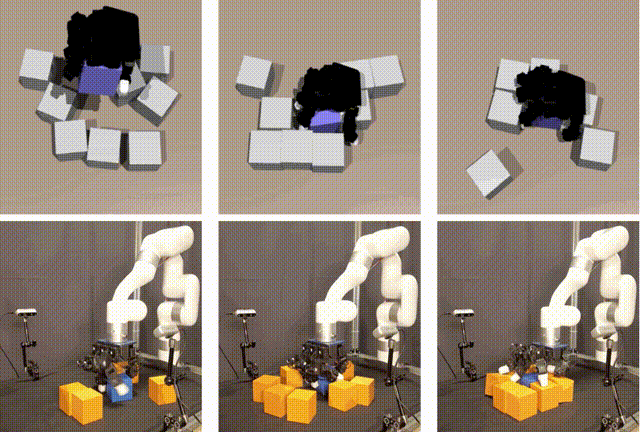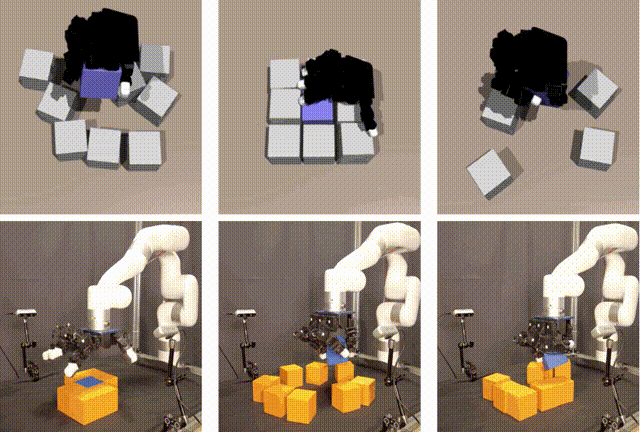
T(R,O) Grasp: Efficient Graph Diffusion of Robot-Object Spatial Transformation for Cross-Embodiment Dexterous Grasping
International Conference on Robotics and Automation (ICRA) 2026
Use hand-object graph diffusion for cross-embodiment grasp synthesis, achieving 94.83% success with 0.21 s inference.
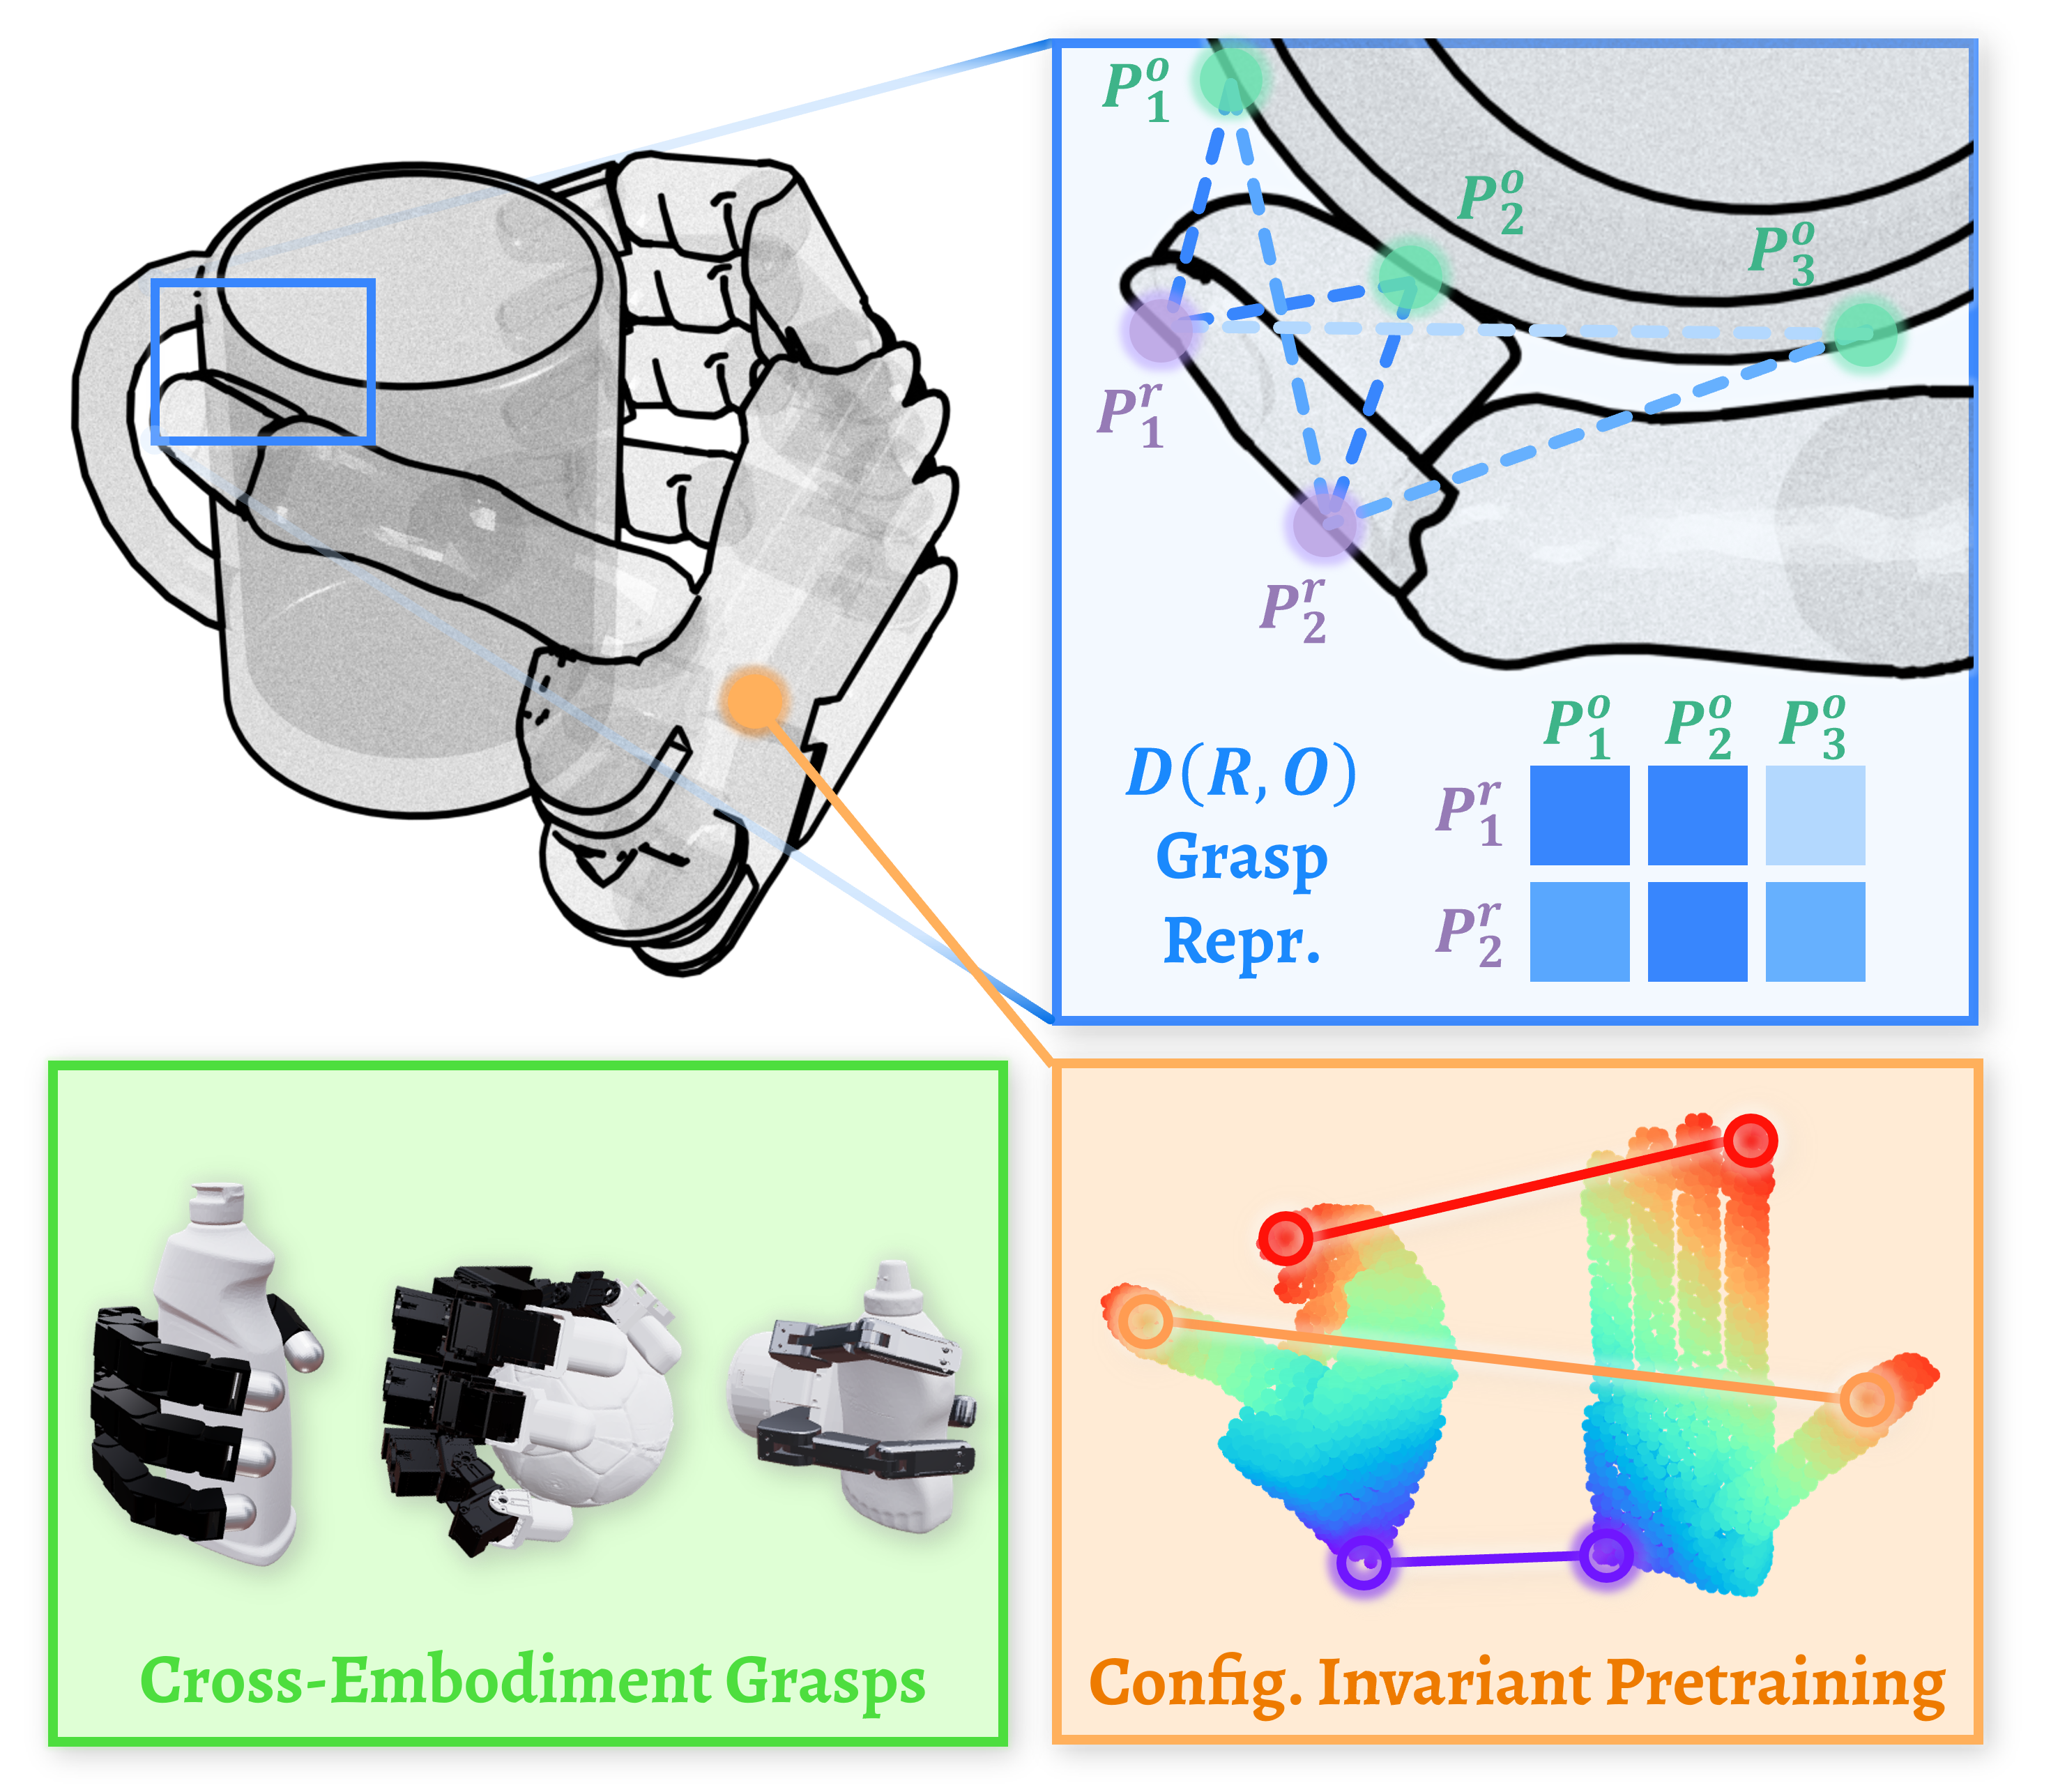
D(R,O) Grasp: A Unified Representation of Robot and Object Interaction for Cross-Embodiment Dexterous Grasping
International Conference on Robotics and Automation (ICRA) 2025
Best Paper Award on Robot Manipulation and Locomotion @ ICRA 2025
Best Paper Award Finalist @ ICRA 2025
Best Robotics Paper Award @ CoRL 2024 Workshop MAPoDeL
Represent robot-object interactions to generalize dexterous grasping across diverse robotic hands and objects.
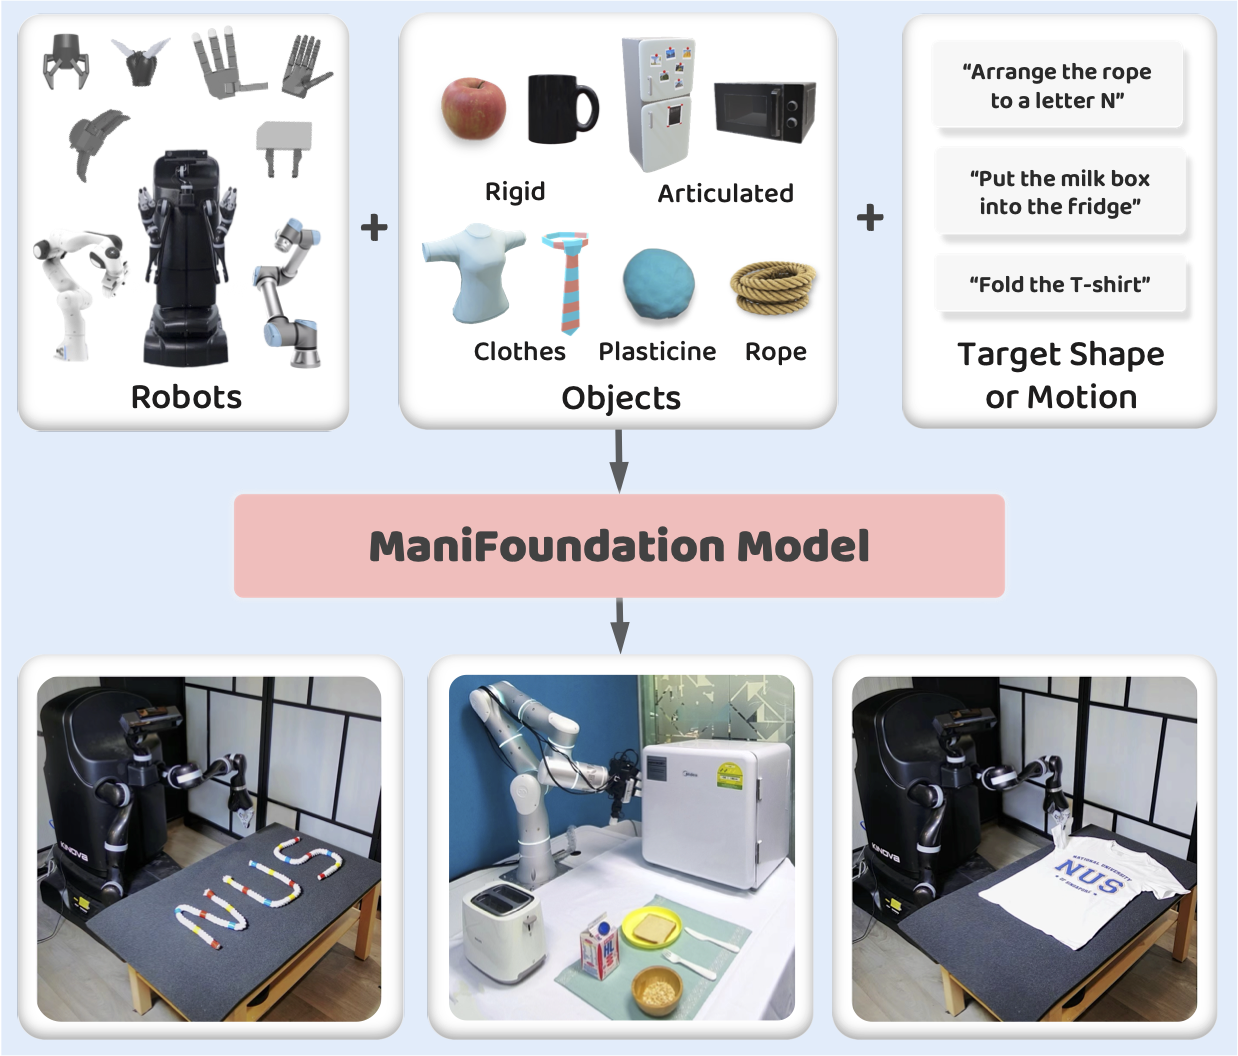
ManiFoundation Model for General-Purpose Robotic Manipulation of Contact Synthesis with Arbitrary Objects and Robots
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2024
Oral Presentation
Introduce a framework taking contact synthesis as a unified task representation that can generalizes over objects, robots, and manipulation tasks.
Collaborative Projects
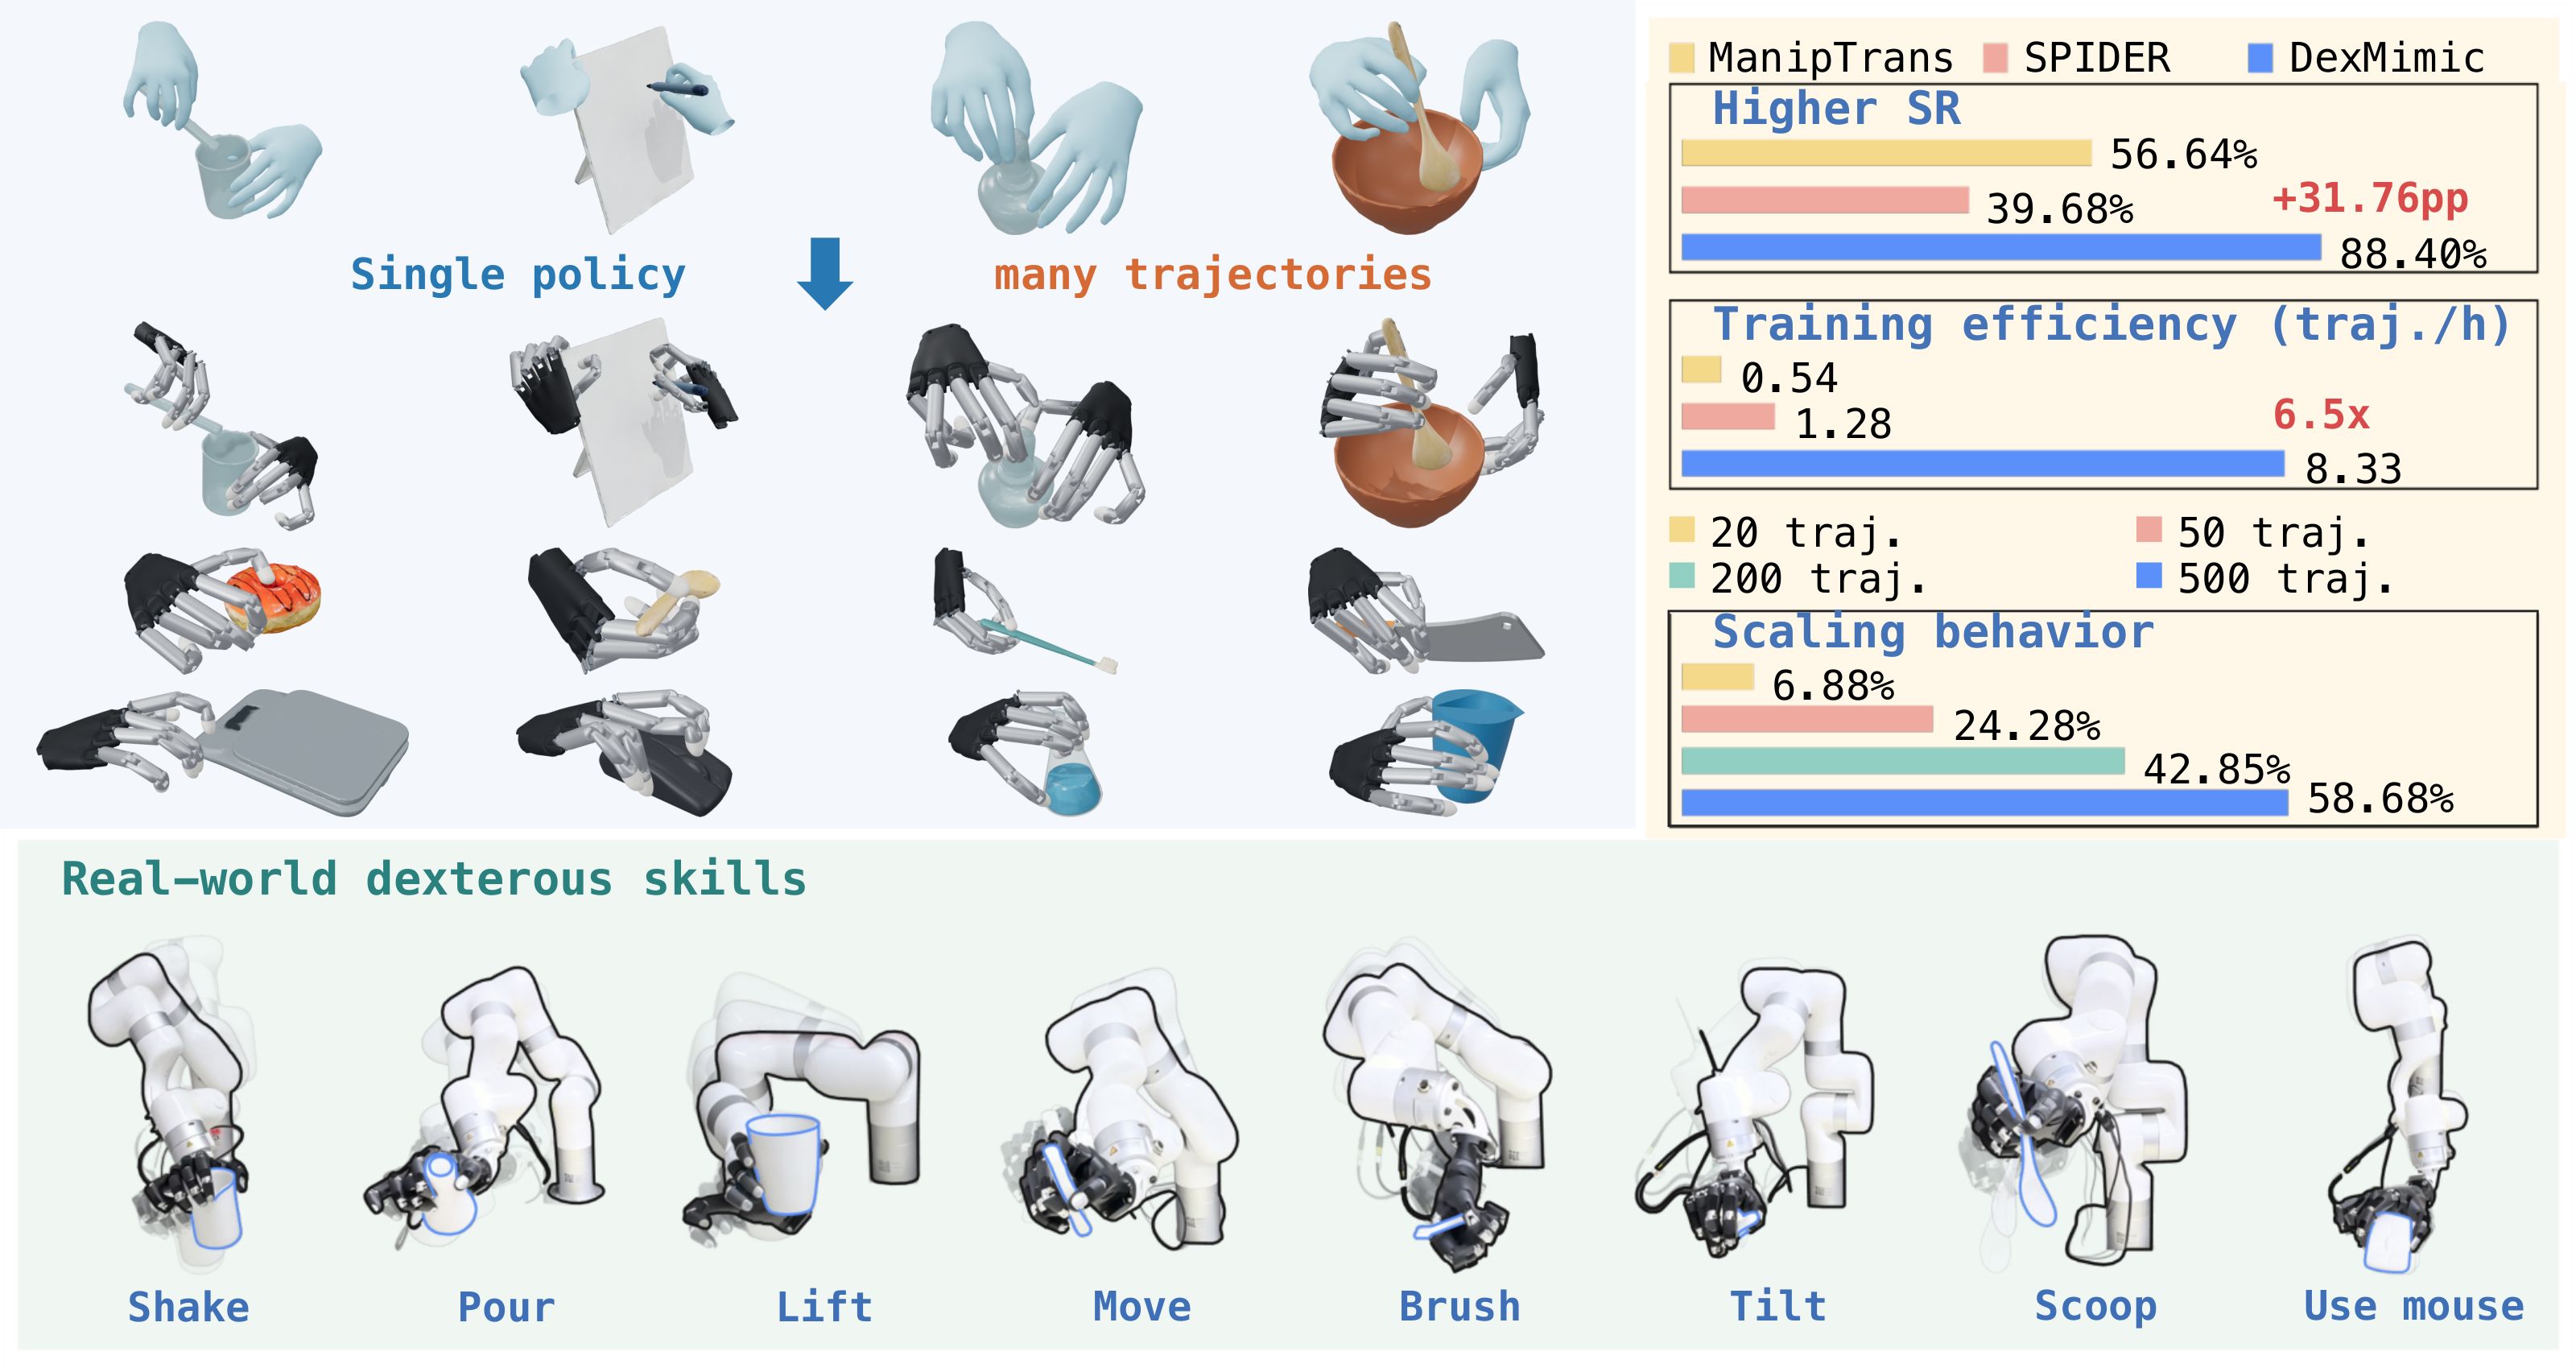
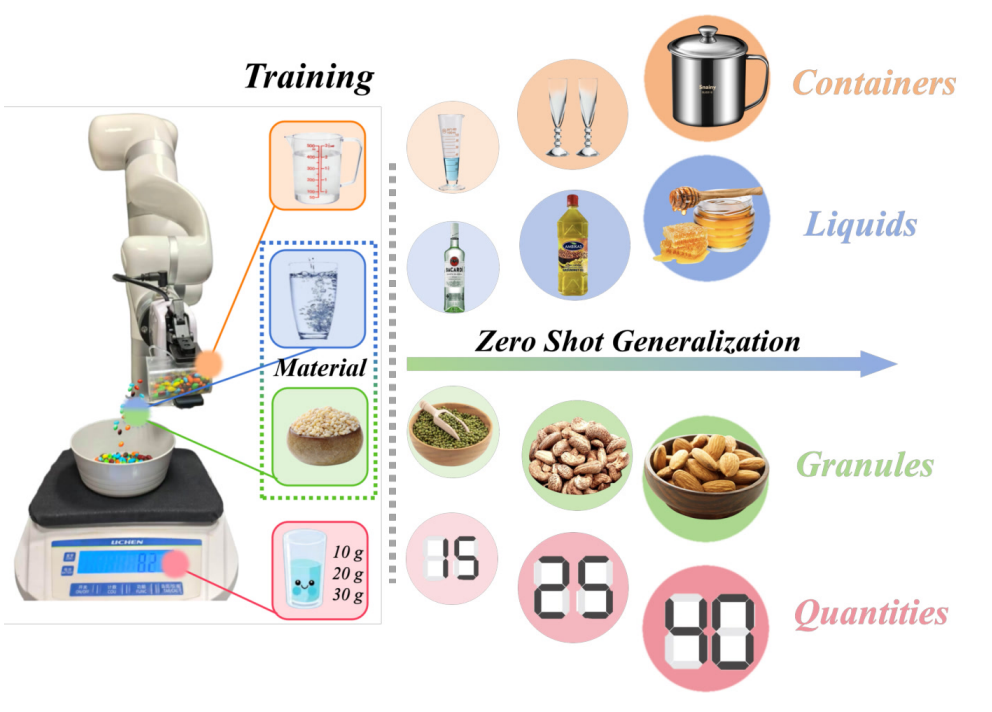
QuaMa: Extending Skill Learning with Delta Dynamics Modeling for Precise and Generalizable Quantitative Manipulation
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026
Combine skill learning, delta dynamics, and online action refinement for precise pouring across unseen containers, materials, and targets.
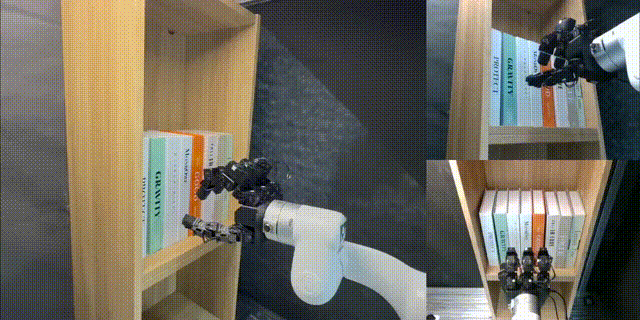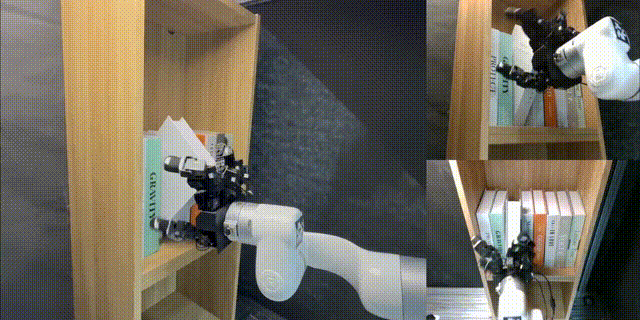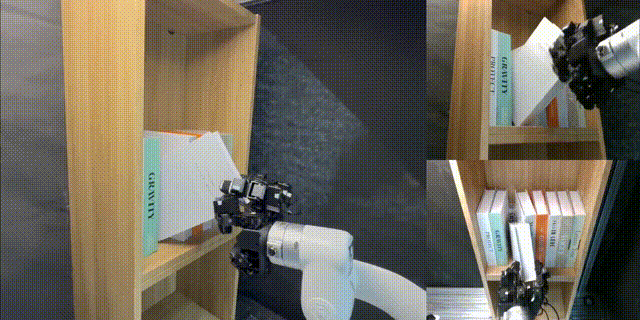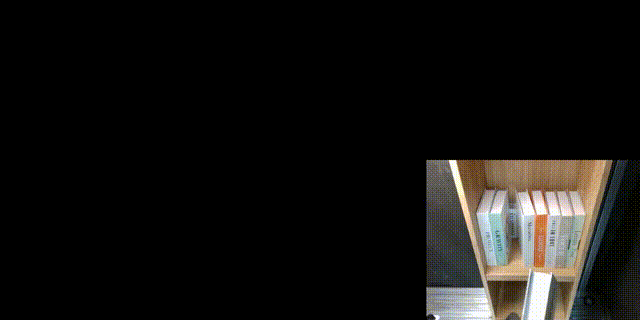
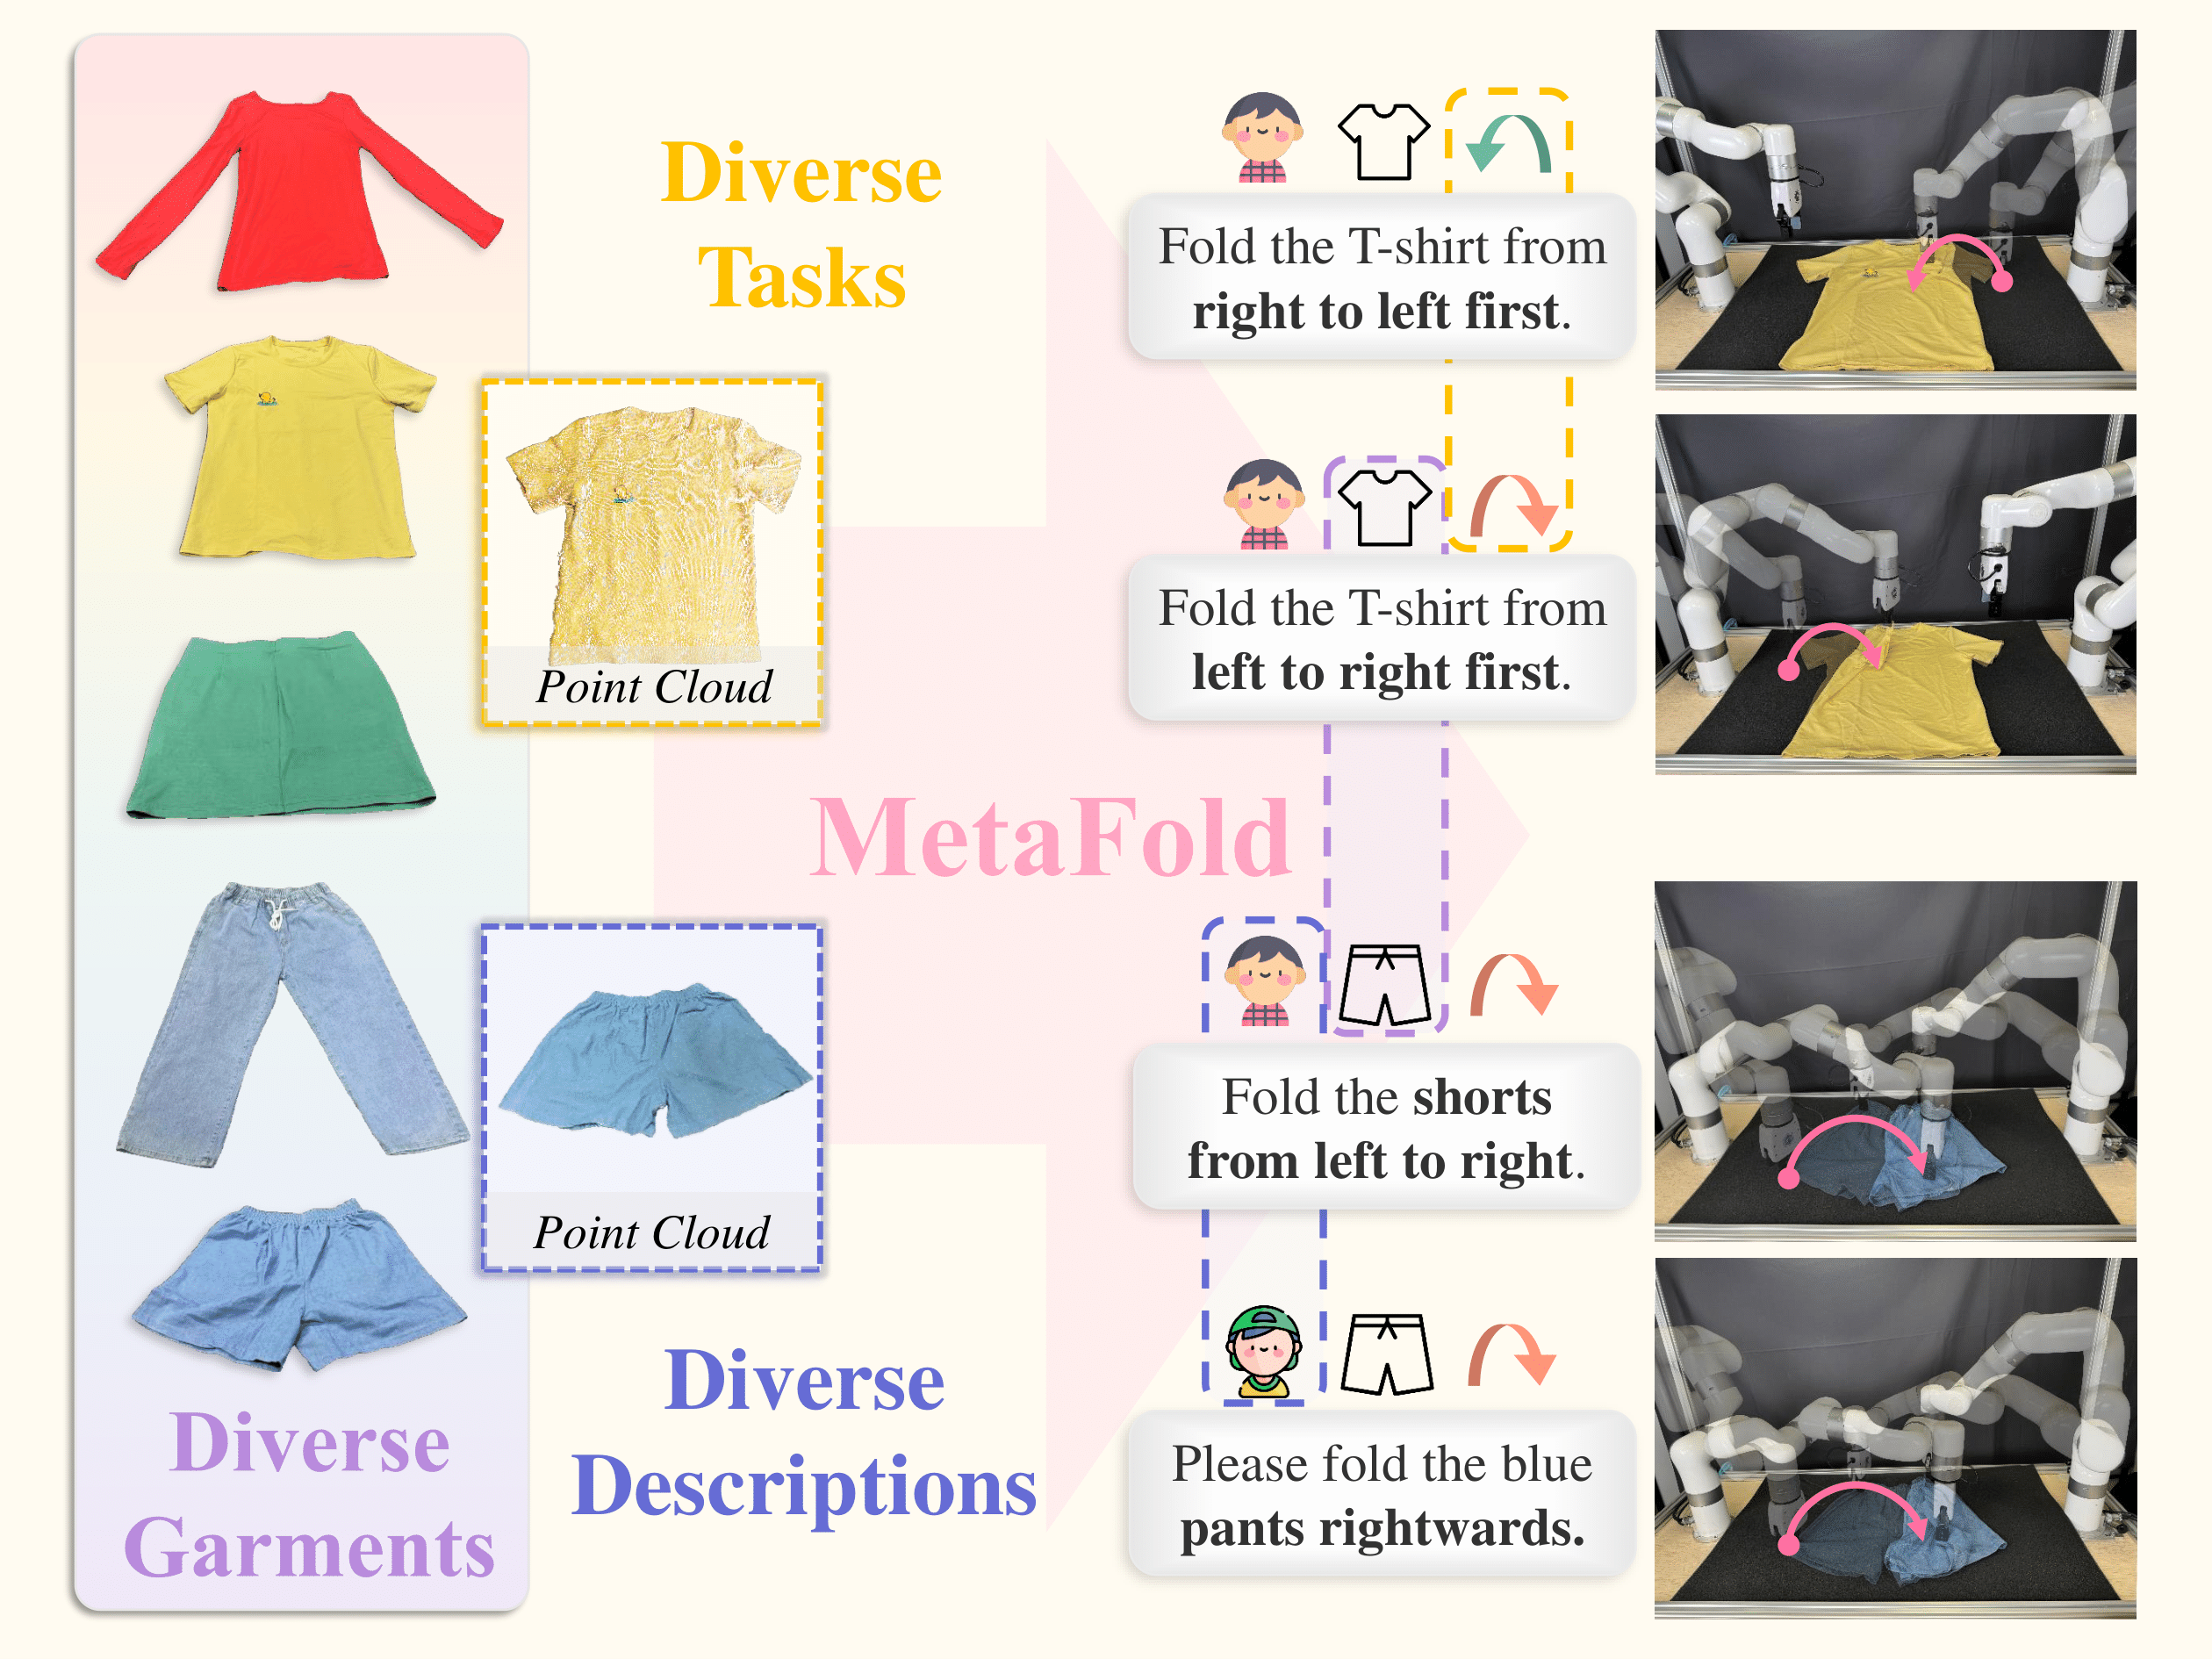
MetaFold: Language-Guided Multi-Category Garment Folding Framework via Trajectory Generation and Foundation Model
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025
Oral Presentation
Disentangle folding tasks into language-guided point cloud trajectory generation and low-level action prediction.
TelePreview: A User-Friendly Teleoperation System with Virtual Arm Assistance for Enhanced Effectiveness
Best Paper Award @ ICRA 2025 Workshop on Human-Centric Teleoperation
Spotlight Presentation @ ICRA 2025 Workshop on Human-Centric Teleoperation
Use data gloves, IMU sensors, and previews of future robot motion for low-cost, more effective teleoperation data collection.
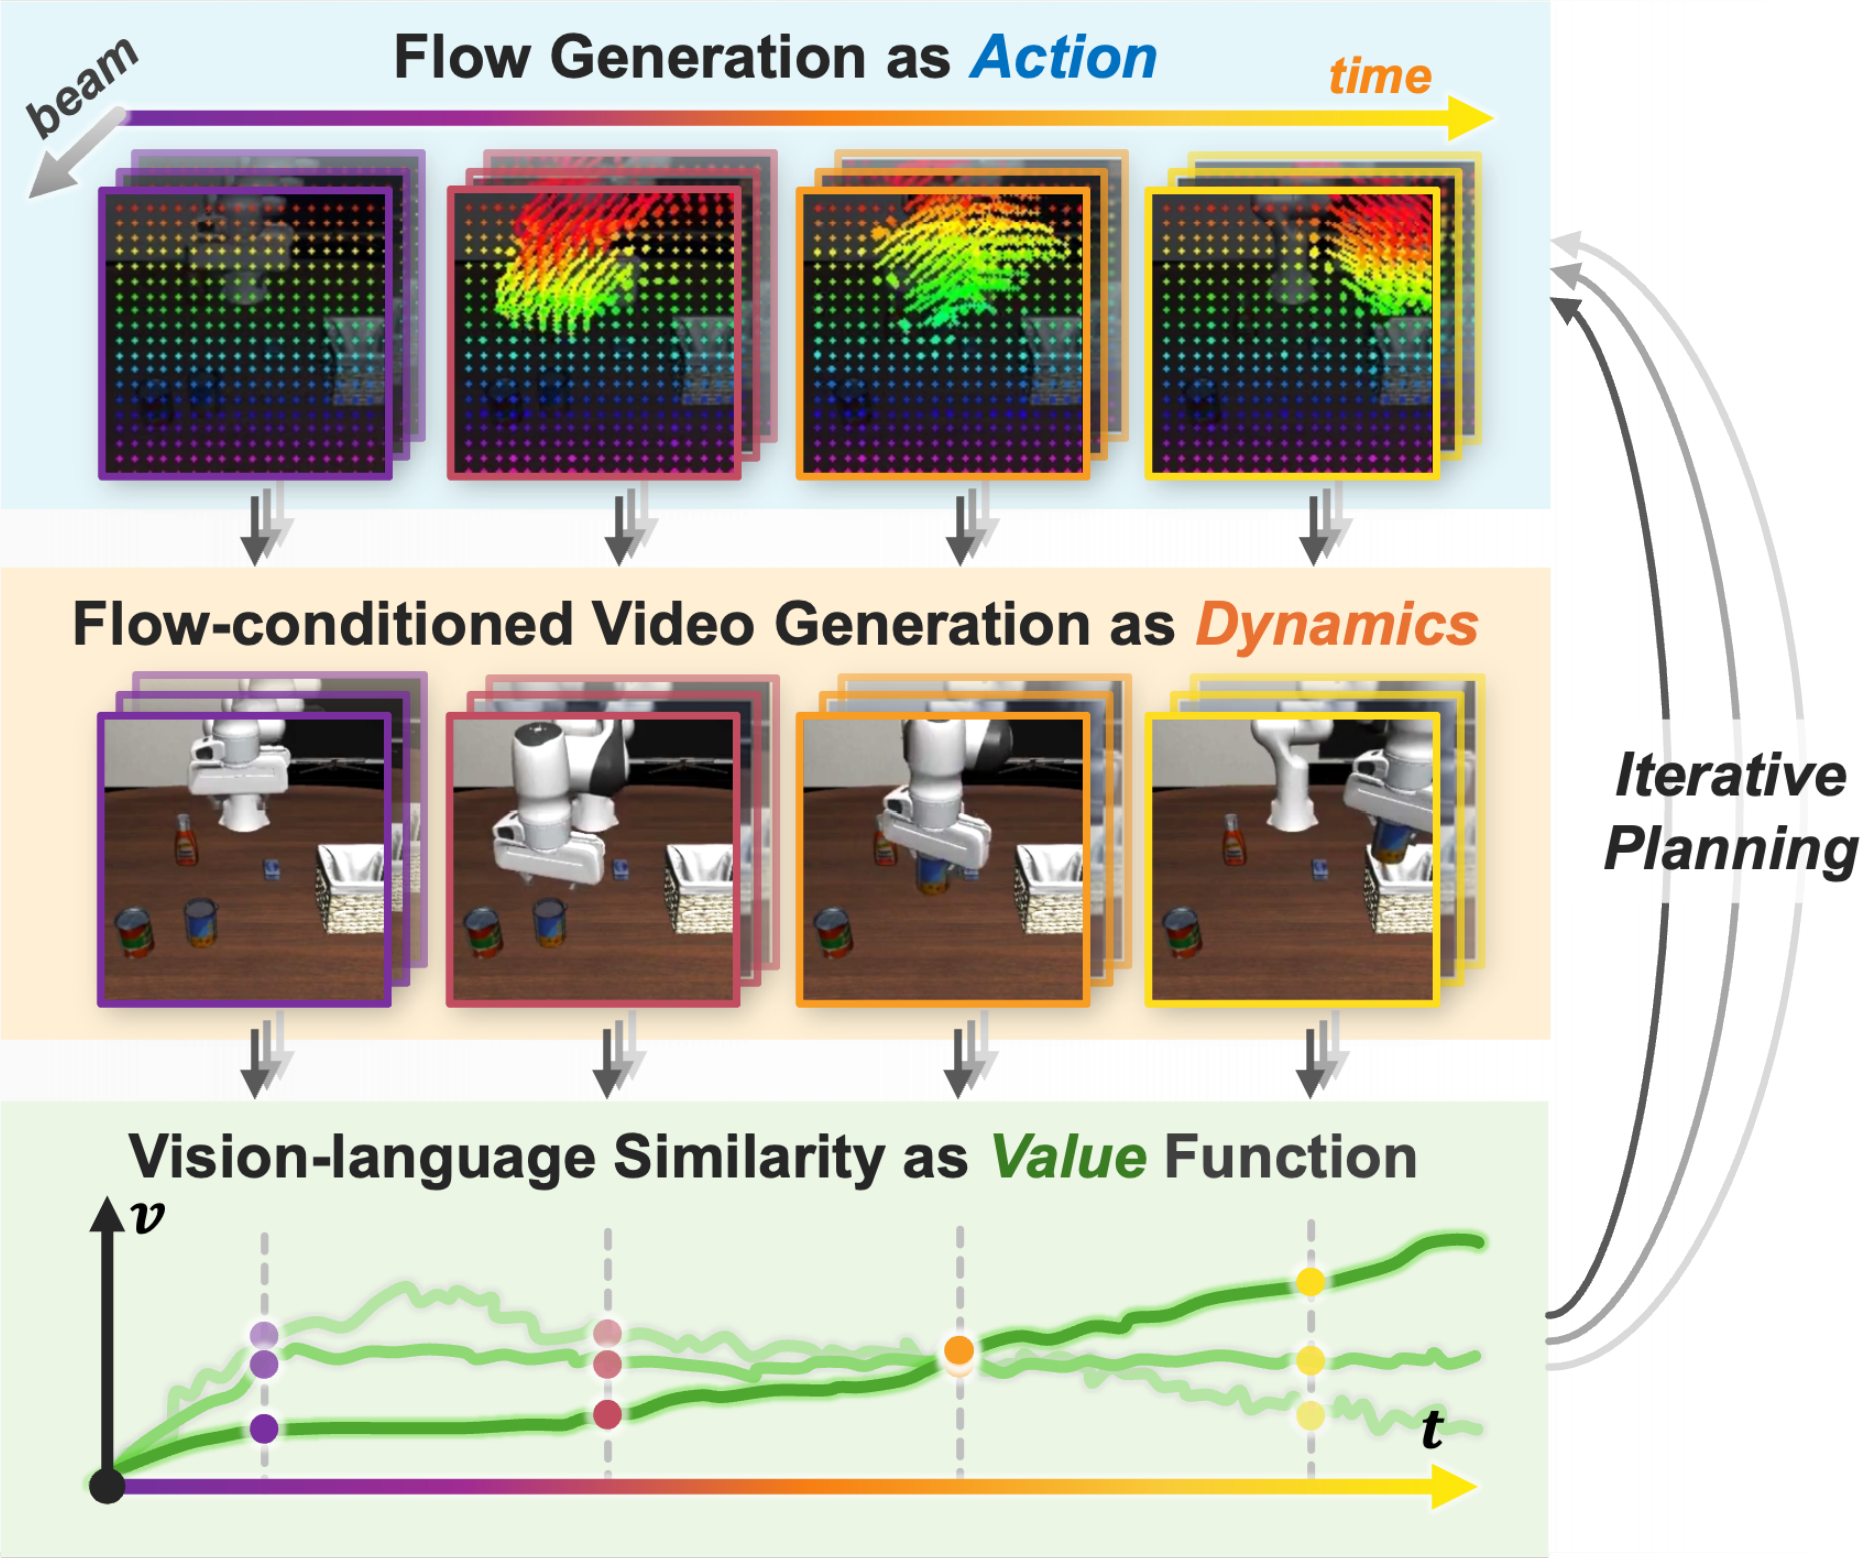
FLIP: Flow-Centric Generative Planning for General-Purpose Manipulation Tasks
International Conference on Learning Representations (ICLR) 2025
Oral Presentation @ CoRL 2024 Workshop LEAP
Propose flow-centric generative planning (FLIP) as an interactive world model for general-purpose model-based planning for manipulation tasks.
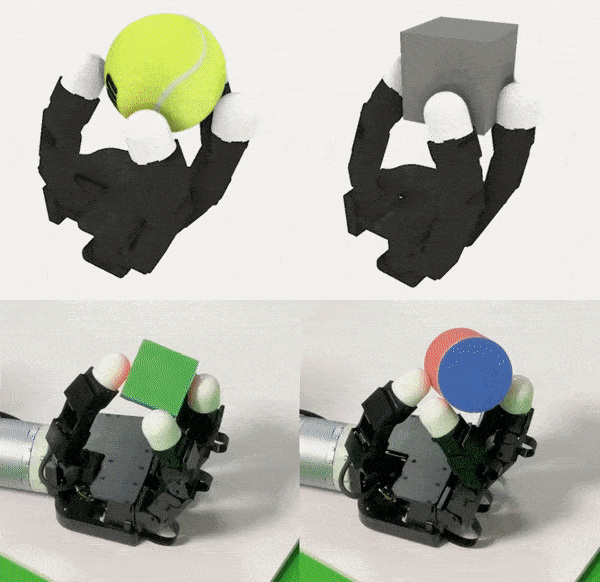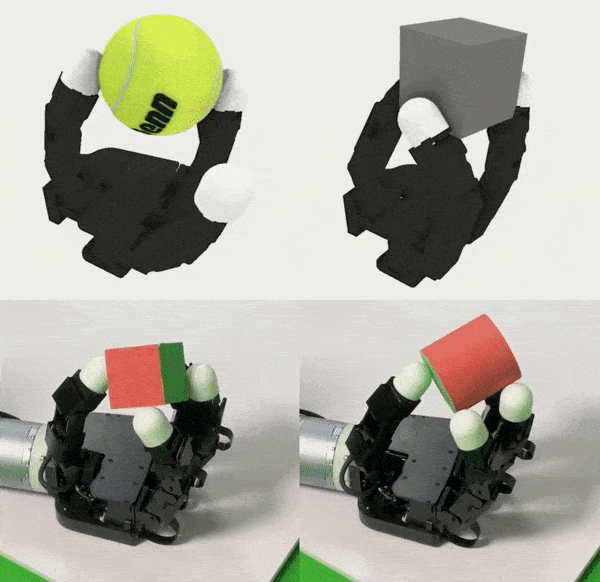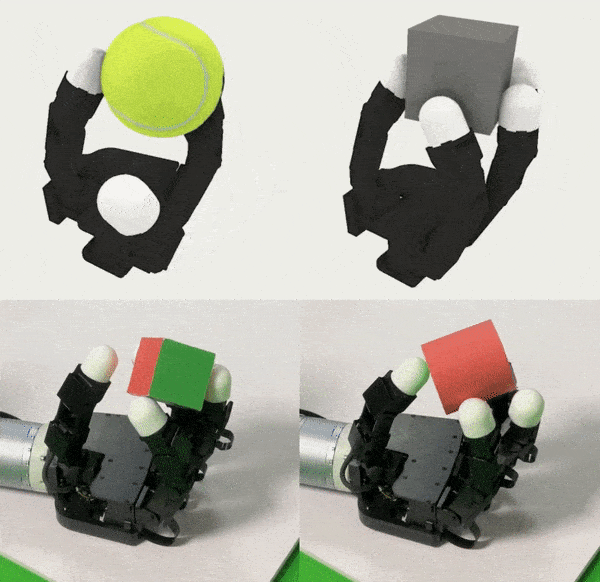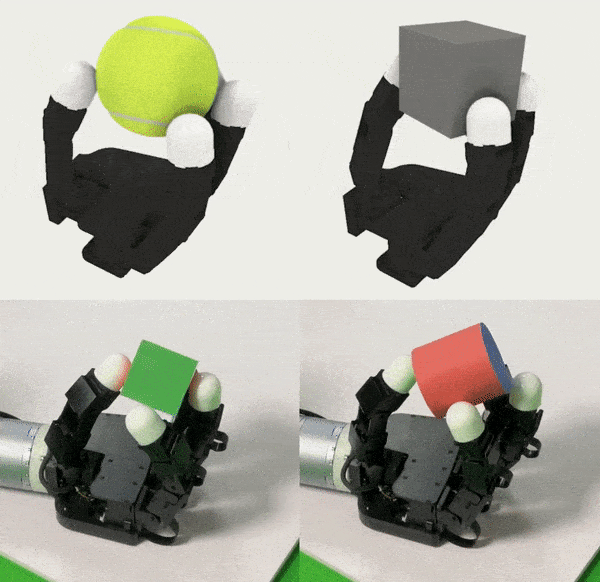
Diff-LfD: Contact-aware Model-based Learning from Visual Demonstration for Robotic Manipulation via Differentiable Physics-based Simulation and Rendering
Conference on Robot Learning (CoRL) 2023
Oral Presentation
Learn dexterous manipulation from human videos using differentiable rendering for pose and shape estimation and simulation for contact generation.
Publications
Alumni
Jingxiang Guo (intern 2024), PhD student, National University of Singapore
Zhenyu Wei (intern 2024), PhD student, University of North Carolina at Chapel Hill
Services
Conference Reviewer
- IEEE International Conference on Robotics and Automation (ICRA)
- IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
- Conference on Robot Learning (CoRL)
- International Conference on Learning Representations (ICLR)
Journal Reviewer
- IEEE Transactions on Robotics (T-RO)
- IEEE Robotics and Automation Letters (RA-L)
- IEEE/ASME Transactions on Mechatronics (TMECH)
Teaching
- Teaching Assistant, CS4278/CS5278 Intelligent Robots: Algorithms and Systems, NUS, Fall 2025. Course Project, PyBullet Tutorial.